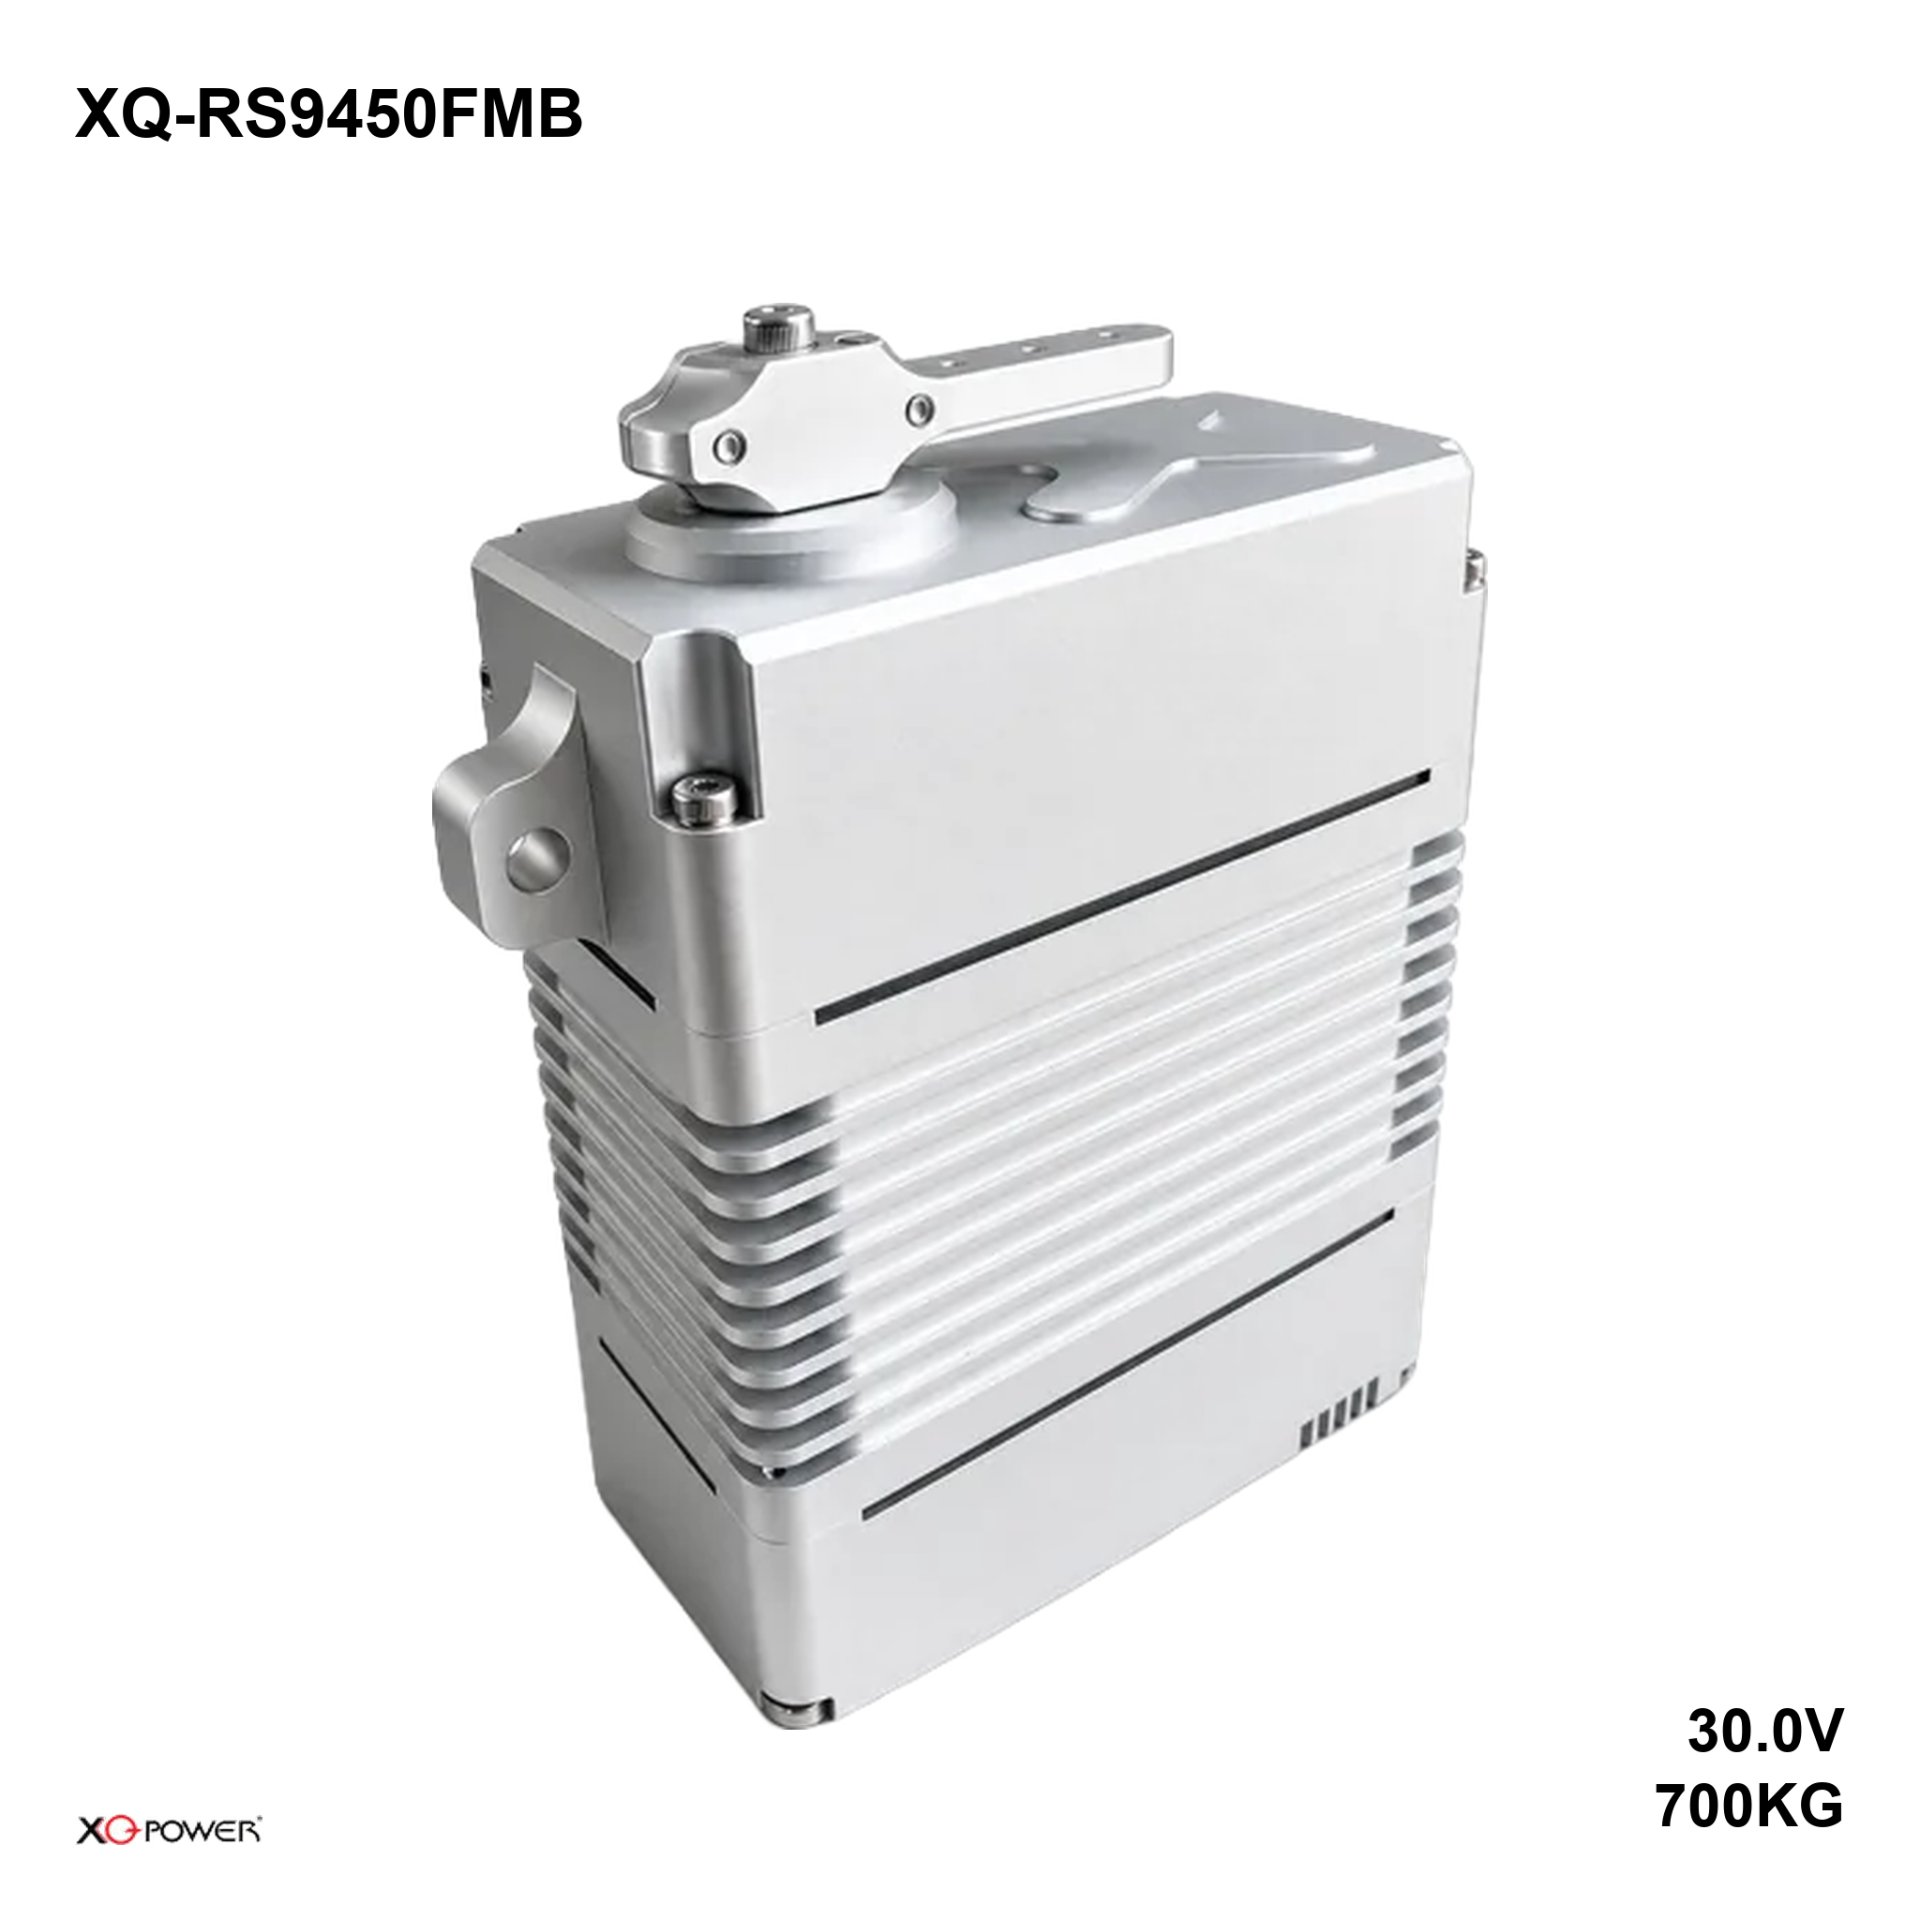
XQ-RS9450FMB — 700 kg·cm (68.6 N·m) mounted on its side, on RS485 Modbus, 22.5 A at stall A brushless motor drives a steel train onto a 25T, φ11.98 mm output carried in eight ball bearings, inside a 100 × 50 × 97 mm machined aluminium case at 895 g. The ears sit on the long sides so the unit bolts flat against a plate with the output facing out. The input stage is an RS485 Modbus node, so a PLC programs the axis in the same environment as the rest of the machine.
The unit gives 560 kg·cm on 24 V, 650 kg·cm on 28 V and 700 kg·cm on 30 V, with speed and current at all three rails. Rated and tested to inspection specification X9_9450.05, dated 2025-02-22.
| Peak stall torque700 kg·cmat 30 V · 9721.2 oz-in · 68.6 N·m | Speed0.21 s/60°at 30 V · 0.30 s at 24 V | Supply24–30 Vthree published points |
| ControlRS485 ModbusRS485 Modbus · 360° across 1000–2000 µs | Envelope100 × 50 × 97 mm122.7 mm across the ears · 25T-φ11.98 | Mass895 g8 ball bearings · no mechanical stop |
Is the XQ-RS9450FMB the right servo for your joint?
At 700 kg·cm the joint has stopped being a component and become a structural part of the machine. Modbus makes it a node a PLC writes to, which is how a heavy axis gets programmed alongside the drives that surround it. The eight bearings and the φ11.98 mm output are what let the case carry that load into a plate.
Travel is 360° across the 1000–2000 µs span, and section 3-4 reads No Limit. On a joint this strong the end positions belong to the machine: a 700 kg·cm output driven into a hard stop will damage the structure it is bolted to.
Specify this unit when
- The controller is a PLC or drive that runs Modbus RTU
- The axis carries several hundred kg·cm and is part of the structure
- The joint bolts to a plate with the output facing out
- The supply can hold 24–30 V at 22.5 A
- The move needs the better part of a full turn
Specify a different unit when
- There is no Modbus master on the machine
- The mechanism relies on the servo to find its end stops
- The supply sags below 24 V under load
- The bay cannot take 100 × 50 mm of case and 122.7 mm across the ears
- The joint needs more than 700 kg·cm
Torque and speed at 24, 28 and 30 Volts
Rows 4-1 to 4-13: locked-shaft torque, no-load speed, no-load current and stall current. The stall column on this frame needs close attention.
| Supply | Peak stall torque | No-load speed | No-load current | Stall current |
|---|---|---|---|---|
| 24 V | 560.0 kg·cm | 0.30 s/60° | 400 mA | 18 A |
| 28 V | 650.0 kg·cm | 0.25 s/60° | 430 mA | 21 A |
| 30 V | 700.0 kg·cm | 0.21 s/60° | 450 mA | 22.5 A |
700 kg·cm at 30 V and 0.21 s per 60°, 650 kg·cm at 28 V, 560 kg·cm at 24 V. Twenty-two and a half amps at 30 V stall is the figure that decides the cable, the contactor and the supply, and it sits in the same row as the torque.
No-load current runs 400 to 450 mA across the three rails. The motor is not the constraint on this frame; the wiring is. A pair sized for 10 A will not carry 22.5 A on a long run without dropping the joint into the 28 V column.
Fit: envelope, spline and mass
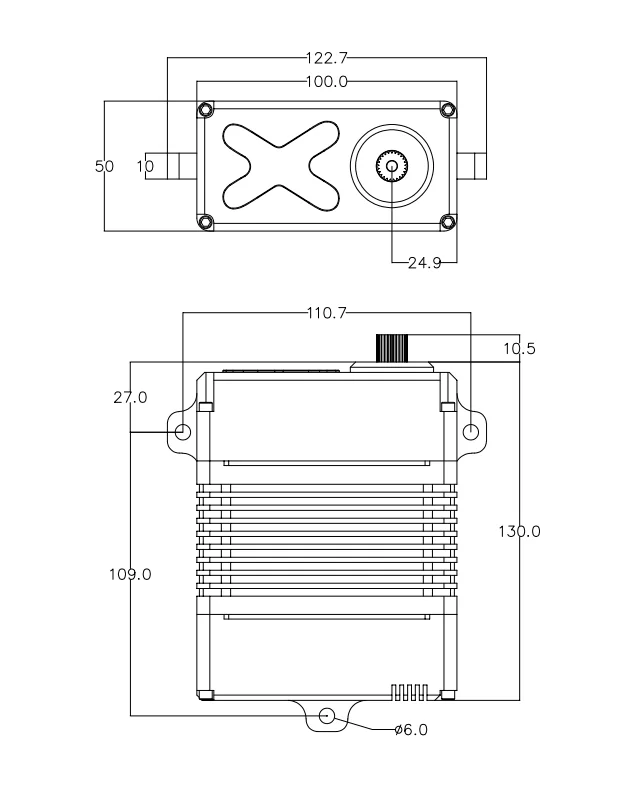
100 × 50 × 97 mm, 122.7 mm across the mounting ears and 130.0 mm overall height, with Ø6.0 holes on 15 mm ears. The ears are on the long sides, so the plate is the load path: a 2 mm sheet will flex under 700 kg·cm and take the case with it.
25T at φ11.98 mm with a metal arm supplied. This is the heaviest output in the range below the 1000 kg·cm frame, and the spline is what transfers the torque without a keyway.
895 g. On a static axis the mass is a mounting question; on a moving axis it is the number the drive has to accelerate. Either way the plate has to carry it.
Drive, current and heat
22.5 A at stall on 30 V, 450 mA at no load. The ratio is what this frame is for: the gear train does the work and the motor stays small, so the current is a wiring problem.
Dead band 3 µs, neutral 1500 µs, window 500–2500 µs, all customizable. On Modbus these become the resolution and the zero point of the position register, and they sit in the commissioning record with the slave address.
The case is a machined block with fins on the long faces and the drive mounted against them. At 22.5 A the fins matter: a joint holding a load stationary pulls near stall current and the case does the cooling, which is why section 2-2 stops at 60 ℃.
Eight bearings on the output is the most we put in any frame below 1000 kg·cm. That is what lets the case take 700 kg·cm without the output shaft deflecting under load, and it is why the arm needs no outboard support at this torque.
Sealing and environment
Section 3-11 records splash resistance as Yes on a machined aluminium case with sealed joint faces. A higher water-protection grade is built to order, and the class and test standard are agreed at order stage.
The J30J-15TJL connector sits outside the sealed volume, and on a 22.5 A joint it carries heavy gauge wires. Keep the plug dry or seal it to the same standard, and dress the harness down and away so water leaves the entry.
−30 ℃ to 60 ℃ operating, −30 ℃ to 70 ℃ storage. The top of that range is spent quickly on a joint holding a load without moving, because the case is sealed and the fins are the only path out.
Full specification
The complete sheet for the XQ-RS9450FMB, in the order it appears on inspection document X9_9450.05, dated 2025-02-22: measured figures throughout, and where we have none the row says so.
| Model | XQ-RS9450FMB |
| Peak stall torque (SI) | 68.6 N·m at 30 V |
| Voltage range | 24–30 V |
| Control interface | RS485 Modbus |
| Amplifier | Digital controller |
| Rotating direction | CCW (1000–2000 µs), customizable |
| Angle of limit | None, no mechanical stop |
| Motor | Brushless |
| Gear train | Steel |
| Bearing system | 8 ball bearings |
| Output spline | 25T, φ11.98 mm |
| Horn supplied | Metal arm supplied |
| Case | Aluminium CNC, all-metal case |
| Dimensions | 100 × 50 × 97 mm |
| Weight | 895 g |
| Cable length | J30J-15TJL connector, purchased separately |
| Operating temperature | −30 ℃ to 60 ℃ |
| Storage temperature | −30 ℃ to 70 ℃ |
| Sealing | Splash-proof · higher water-protection grade built to order |
| Specification revision | X9_9450.05, dated 2025-02-22 |
Download the XQ-RS9450FMB datasheet (PDF)
The inspection sheet for this model, including the dimensional drawing and the control-signal table, is available as a PDF.
|
XQ-RS9450FMB inspection specification Revision X9_9450.05 · dated 2025-02-22 · PDF |
Download PDF |
If you need the drawing in DWG, a STEP model, or the control-signal table as a separate sheet, tell us which format your CAD system uses and we will send that instead.
Variants, samples and OEM work
The pulse build of this case is S9450F, the CAN build S9450FC and the TTL build S9450FTTL. The base-mount 700 kg·cm frame is S9450D and the 1000 kg·cm unit is S9750D.
The side-mount case is also built with a pulse input, a CAN node and a TTL input, all on the same 122.7 mm ear spacing and the same 25T φ11.98 mm output. The interface is chosen at quotation and the harness is built to it.
For OEM and ODM work on the XQ-RS9450FMB we start from five numbers: the torque you need at your speed, the supply you actually run, the interface your controller speaks, the envelope the joint allows, and the duty cycle. Send those and we answer one of three ways — the XQ-RS9450FMB covers it as stock at 700 kg·cm, a build of the same 100 × 50 × 97 mm frame does, or the axis needs a different frame. Send the XQ-RS9450FMB numbers to the engineering team.
Quick facts and cross-reference
The rows below are what to quote for the XQ-RS9450FMB: 700 kg·cm (68.6 N·m) on 24–30 V with RS485 input, plus the two makes buyers usually weigh it against.
| Model | XQ-RS9450FMB |
| Peak stall torque | 700 kg·cm · 68.6 N·m at 30 V |
| Voltage range | 24–30 V |
| Control interface | RS485 Modbus |
| Speed | 0.21 s/60° |
| Mass / envelope | 895 g · 100 × 50 × 97 mm |
| Also described as | RS485 servo, Modbus servo, RS-485 bus actuator, daisy-chain actuator |
Buyers often arrive here from a CubeMars AK series or a MyActuator RMD-X series, which are built around 24-48 V robot-platform rails as integrated actuators; the XQ-RS9450FMB is 700 kg·cm (68.6 N·m) on 24–30 V, so put the two on the same rail and in the same unit before comparing torque.
| Cross-reference | CubeMars AK series, MyActuator RMD-X series |
| Their typical rail | built around 24-48 V robot-platform rails as integrated actuators |
| This model | 700 kg·cm (68.6 N·m) on 24–30 V, RS485 input |
FAQ
The sheet header says 450 kg·cm. Why is the page 700?
Rows 4-4, 4-8 and 4-12 give 560, 650 and 700 kg·cm at 24, 28 and 30 V. The header carries an earlier rating for this frame and was not updated when the winding changed. We publish the measured rows and this page quotes them.
What current does the feed have to carry?
22.5 A at stall on 30 V, 21 A on 28 V and 18 A on 24 V, with 450 mA at no load. Size the cable and the contactor on the stall figure for every joint that can load at the same moment, and check the drop at the far end of the run.
How does Modbus work with a joint this size?
The master writes a position value to the node and reads back what it needs. Address, baud rate, parity and the register map are agreed at order stage, documented in the protocol note that ships with the unit, and confirmed before the order is accepted.
Is there a stop inside the case?
No. Section 3-4 reads No Limit and 5-5 gives 360° across the 1000–2000 µs span. At this torque the machine must own its limits, because the servo will drive through a soft stop and break what it finds.
Is a lead included?
No. The unit carries a J30J-15TJL connector and the mating lead is a separate purchase. Give us the length, the pinout and the gauge your installation needs and the harness is quoted with the servo.
What does it weigh, and what has to hold it?
895 g in a 100 × 50 × 97 mm case, 122.7 mm across the ears. The plate takes 700 kg·cm as a bending load, so it wants thickness and a backing rib behind the ears.
Is the XQ-RS9450FMB a drop-in replacement for a CubeMars AK series?
No. The CubeMars AK series runs on a different rail and a different frame, while the XQ-RS9450FMB is 700 kg·cm (68.6 N·m) on 24–30 V with RS485 input, so a swap means checking voltage, envelope and travel first. Send the rail and envelope your machine runs and we will say whether the XQ-RS9450FMB frame fits.
What should I compare before choosing between the XQ-RS9450FMB and a MyActuator RMD-X series?
Four numbers decide between the XQ-RS9450FMB and a MyActuator RMD-X series: peak stall torque in N·m, the rail you actually run, stall current, and whether your controller speaks RS485. The XQ-RS9450FMB publishes 700 kg·cm (68.6 N·m) on 24–30 V; put the MyActuator RMD-X series on that same rail and in the same unit before you compare the two.