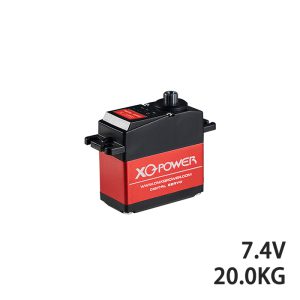
Servo Motors ≤20 kg·cm
Servo motors rated 20 kg·cm or less (≤1.96 N·m) are the small end of the actuator range: compact, fast and light enough for grippers, camera mounts and benchtop mechanisms. They are the first size engineers specify when a design needs precise positioning but only a few hundred grams of payload.
What fits in this torque range
- Parallel and angular grippers, small end effectors
- Camera gimbals and pan-tilt heads
- 3D-printed robot arms and lab dosing fixtures
- Dampers, shutters and light valve actuation
Torque reference
| 20 kg·cm | ≈ 1.96 N·m |
| Typical payload | 0.2–1 kg on a 10 cm arm |
| Holding force | ≈ 19.6 N at a 10 cm radius |
Choosing inside this range
Below 20 kg·cm, speed and resolution usually matter more than raw torque. Check no-load speed, dead band and whether the servo holds position when idle — a 15 kg·cm unit that sags under load is worse than a 12 kg·cm unit that holds.
FAQ
How do I convert kg·cm to N·m?
Multiply by 0.0981. So 20 kg·cm = 1.96 N·m and 5 kg·cm = 0.49 N·m.
Is 20 kg·cm enough for a robot arm?
For a single joint lifting 0.5 kg at 10 cm, yes with margin. For a two-link arm the shoulder needs roughly double the wrist torque, so start at 20–60 kg·cm.
Available interfaces in this range: PWM and TTL serial.
Showing all 11 results