
XQ-BLS325TTL: How to Build a Low-Profile 25kg TTL Servo Network for Compact Robotics
A compact servo becomes easier to scale when the mechanical envelope and communication architecture are designed together. In a small robot, RC mechanism, or distributed automation assembly, the actuator must fit the available height while providing predictable torque, fast response, node addressing, and useful feedback.
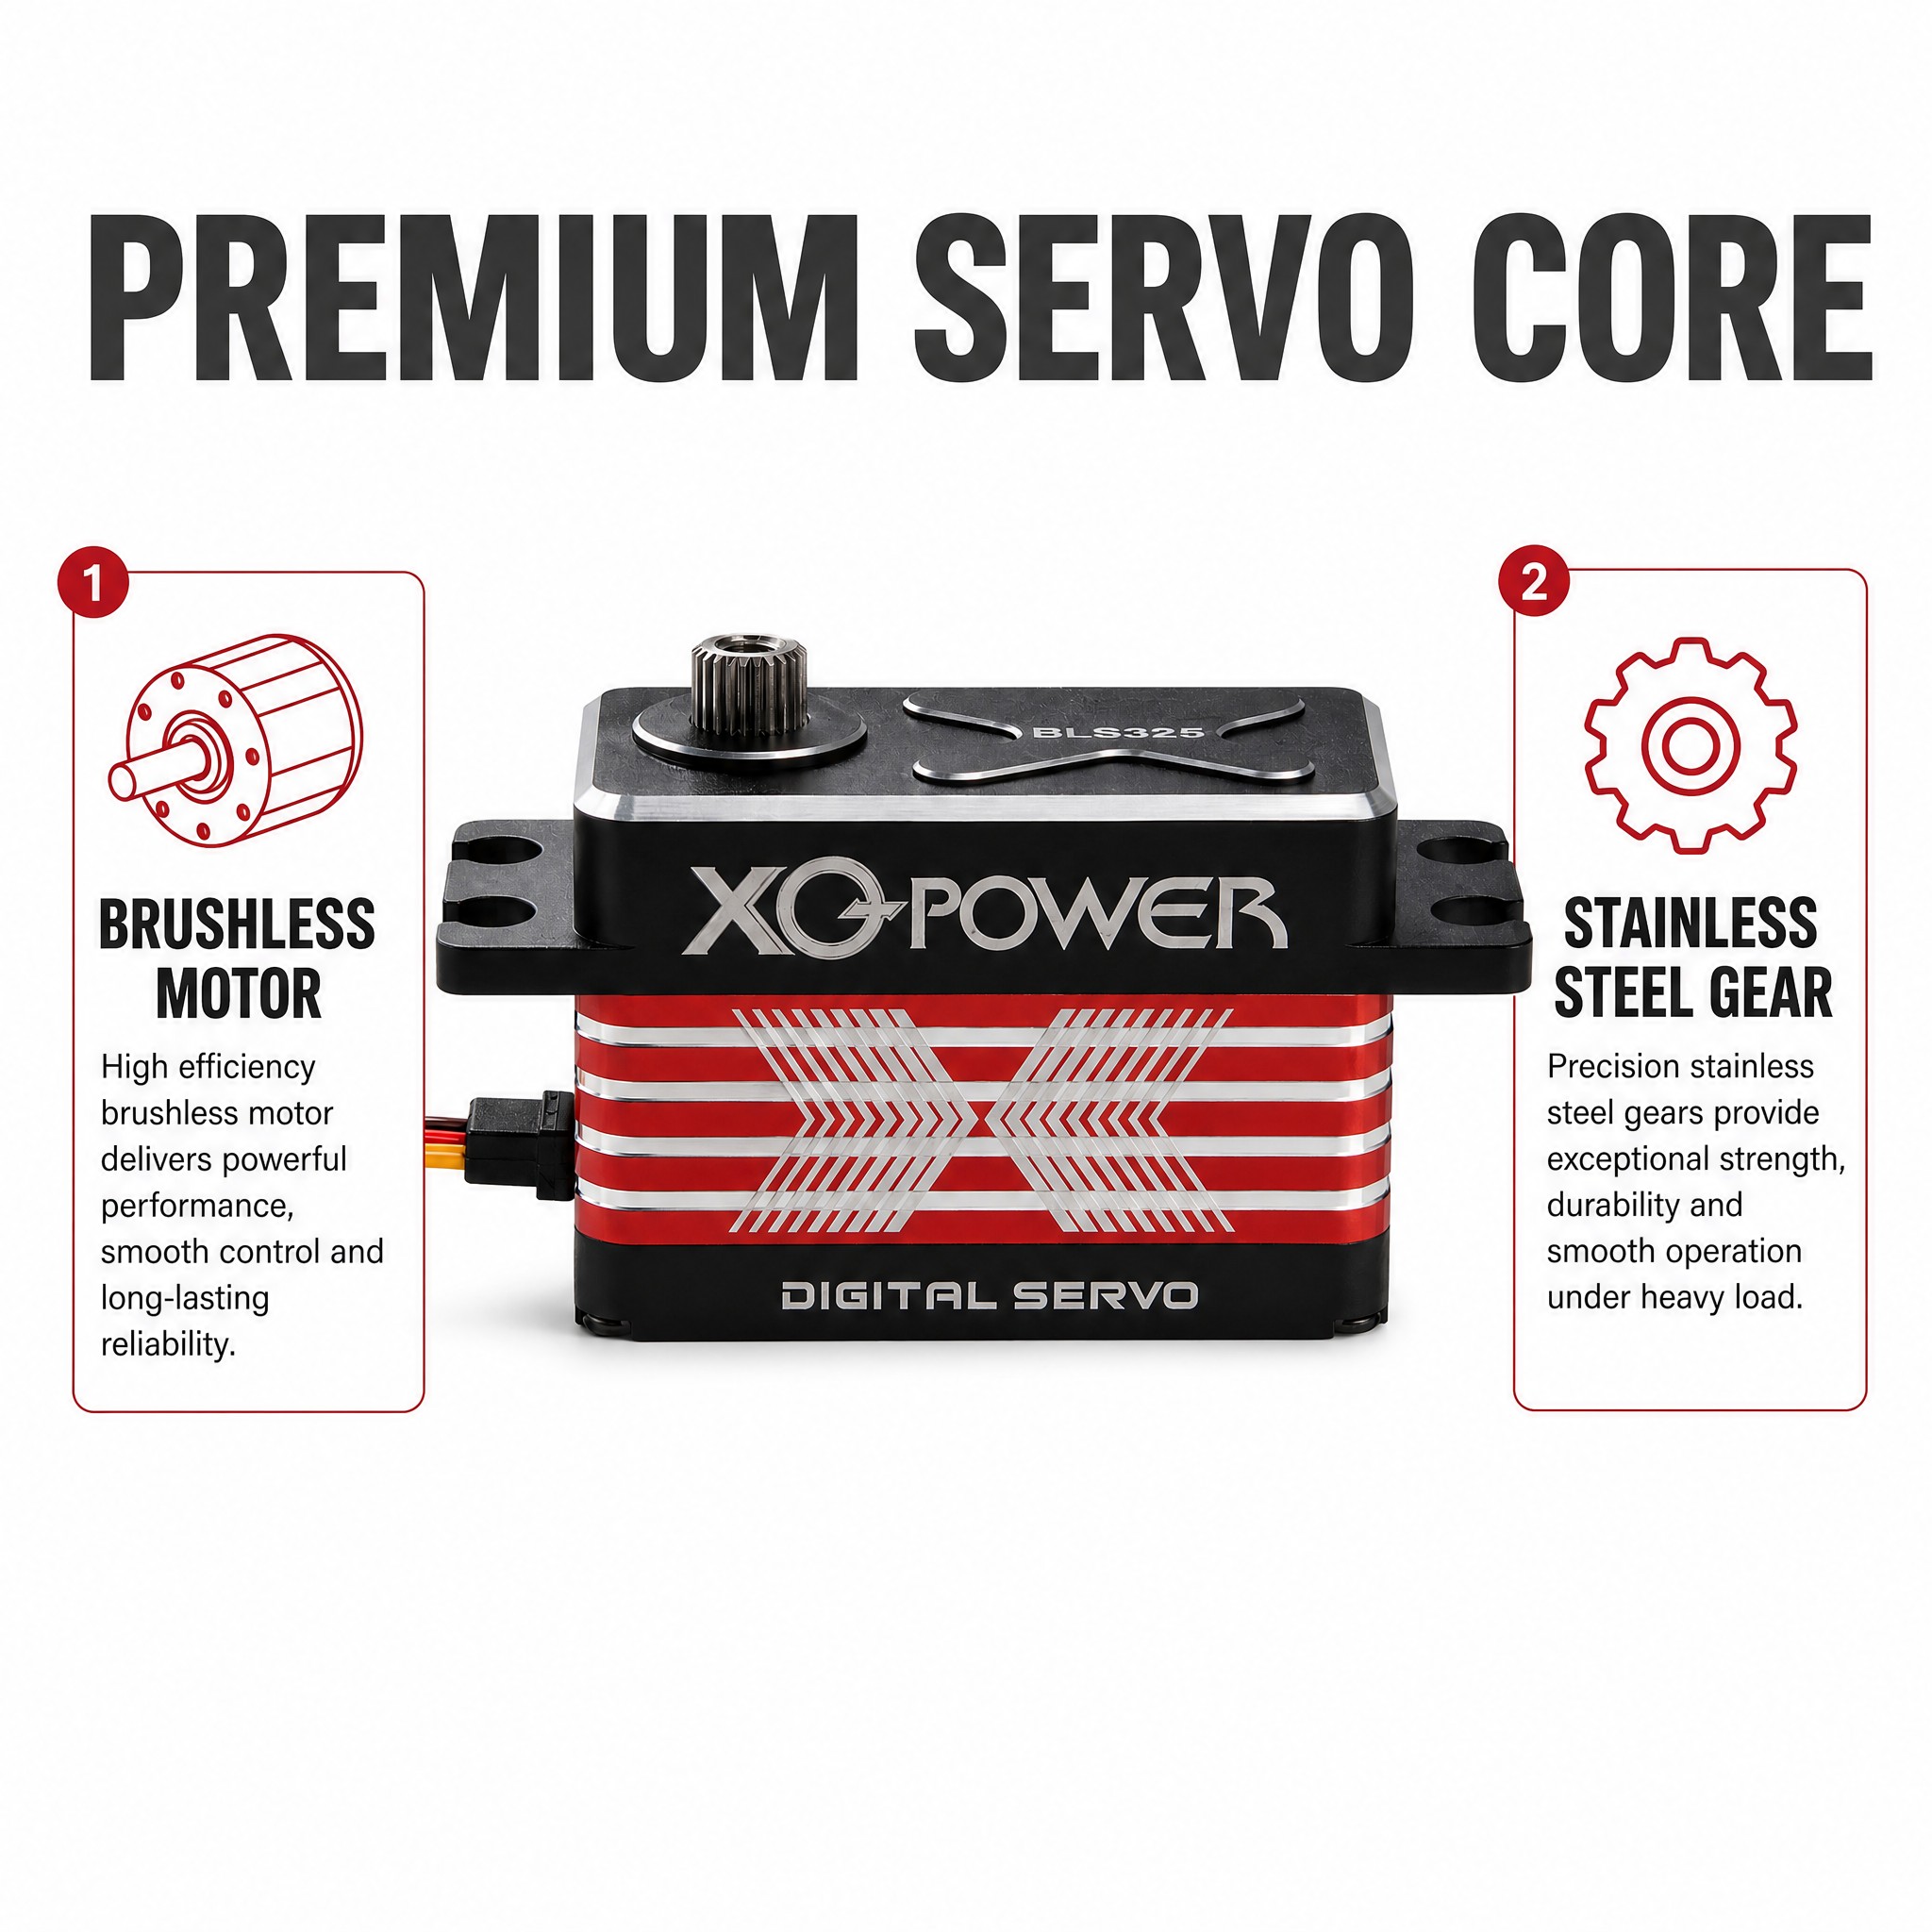
The XQ-BLS325TTL is a low-profile serial-bus brushless servo. The product page identifies a 27mm low-profile chassis, 25kg.cm torque, 0.07 sec/60° speed at 8.4V, TTL daisy-chain communication, real-time telemetry, absolute position feedback, a 12-bit magnetic encoder, a brushless motor, a CNC-machined aluminum case, toughened stainless-steel gears, and dual ball bearings.
This article focuses on integration decisions rather than repeating a catalogue description. It explains how to use a low-profile TTL servo in a multi-axis robot, how to plan the node map, how to organize telemetry, and how to test the complete mechanism before production approval.
Begin with the low-profile installation envelope
The first design step is to map the complete volume available to the actuator. The product page headline identifies a 27mm low-profile chassis, while its specification table also lists 28.5mm. Treat the height as a product-page reference and confirm the current mechanical drawing before finalizing a bracket or enclosure.
Check:
- clearance below the mounting deck;
- body width beside the linkage;
- output shaft and horn position;
- connector direction and cable bend radius;
- mounting-hole access;
- travel of the joint, steering arm, or gimbal;
- nearby battery, controller, and structural parts;
- service access for removal and replacement;
- thermal path around the aluminum case.
A low-profile body can help keep a joint close to the structural plane. It does not remove the need to confirm the exact mounting pattern, output interface, connector position, and final mechanical drawing before releasing the design.
Decide when TTL serial bus is useful
TTL serial bus is worth evaluating when several actuators need to share a signal path while remaining individually addressable.
The BLS325TTL product page identifies daisy-chain communication and synchronized operation through a single signal line. This can be useful when a system includes:
- several compact axes in one robot;
- coordinated steering or camera movement;
- a controller that must identify each actuator;
- a need to retrieve actuator-level feedback;
- repeatable configuration across multiple joints;
- limited space for independent signal wiring.
PWM can be simpler for a single actuator or a small conventional RC installation. TTL serial bus becomes more valuable when node identity, shared wiring, telemetry, and coordinated commissioning are part of the system requirements.
Create the actuator node map before assembly
A multi-axis TTL network should have a documented node map before the wiring harness is finalized.
Record:
- controller and TTL interface location;
- physical axis name;
- assigned actuator node identity;
- daisy-chain order;
- signal and power cable route;
- mechanical orientation and direction;
- travel limits and neutral position;
- required telemetry fields;
- communication timeout and recovery behavior;
- replacement procedure for one actuator.
Use one axis name consistently on the actuator label, cable label, controller configuration, HMI, assembly drawing, and maintenance report. Clear naming makes node replacement and troubleshooting much safer.
Confirm the actual TTL protocol, node-address method, supported node count, data format, timing, and command behavior in the current BLS325TTL documentation. The physical label “TTL” alone does not define every network parameter.
Use telemetry for decisions, not just data collection
The product page identifies real-time telemetry for absolute position, internal temperature, input voltage, and work load. The BLS325TTL also uses a 12-bit magnetic encoder for position feedback.
Define how the control system will use each field:
- compare commanded position with measured position;
- confirm that the joint reached its target;
- detect an unexpected load change;
- monitor temperature during repeated movement;
- identify voltage changes during simultaneous motion;
- compare behavior between axes;
- support maintenance and fault analysis.
Before converting a telemetry value into an alarm or interlock, confirm its units, update rate, resolution, validity state, and behavior during communication loss. Feedback data should be validated in the complete system before it is assigned a safety-critical role.
Separate fast motion data from service data
A shared TTL bus has finite communication time. The controller should allocate traffic according to the importance of each data group.
Define for each axis:
- position command interval;
- position feedback interval;
- temperature polling interval;
- voltage and work-load polling interval;
- diagnostic priority;
- maximum acceptable response delay;
- timeout and retry behavior;
- controller restart behavior;
- data logging requirements.
A high polling rate is not automatically a better control strategy. Fast motion updates and slower service information can use different intervals. A documented schedule is easier to validate than a bus that requests every available value continuously.
Match 25kg.cm to the real joint load
The product page identifies 25kg.cm torque and 0.07 sec/60° at 8.4V. These are actuator performance values, not a universal payload rating.
Calculate the complete joint requirement using:
- payload and downstream mass;
- distance from the output shaft;
- center of gravity;
- gravity torque at the worst angle;
- acceleration and braking;
- linkage or transmission efficiency;
- external contact force;
- friction and misalignment;
- holding time and repeated-cycle duty;
- required engineering margin.
For RC steering, include tire force, steering geometry, stops, and impact events. For a gimbal, include camera balance and rotational inertia. For a compact robot, include the downstream link mass, gravity, acceleration, and cable drag.
A compact actuator can meet the torque calculation and still perform poorly if the bracket flexes, the linkage binds, or the output shaft receives excessive side loading.
Validate the 8.4V performance point
The product page associates the published 0.07 sec/60° response with 8.4V. Validate the voltage at the servo connector while the mechanism runs its representative load profile.
Check:
- battery or regulator capacity;
- voltage drop in the cable and connector;
- simultaneous movement of multiple axes;
- power-up sequence;
- controller restart behavior;
- protection and conductor ratings;
- supply behavior during acceleration and reversal;
- available margin for future load changes.
Do not size the power system from idle current alone. Measure at the actuator during the highest expected combined demand.
Use the mechanical materials in the complete load path
The product page identifies a CNC-machined aluminum case, toughened stainless-steel gears, and dual ball bearings. These features should be evaluated together with the horn, bracket, linkage, and joint frame.
Confirm:
- output-shaft alignment;
- horn and fastener engagement;
- bracket stiffness;
- radial and axial load management;
- external support for overhung linkages;
- mechanical stops and travel limits;
- connector and case clearance;
- service access around the actuator.
Avoid using the servo output shaft as the only structural bearing when the mechanism creates significant side load. A separate support can preserve alignment and reduce unwanted loading.
Commission the BLS325TTL in five stages
Stage 1: Verify one actuator
Connect one XQ-BLS325TTL, assign or confirm its node identity, verify communication, test direction and travel, and record the returned telemetry.
Stage 2: Freeze the axis record
Link the node identity to the physical axis, orientation, cable route, controller parameters, travel limits, and test result.
Stage 3: Add actuators individually
Add the next actuator only after the previous node has a documented configuration. Confirm that each new node responds to its own identity and does not interfere with existing nodes.
Stage 4: Test coordinated motion
Run a low-speed multi-axis sequence. Check command timing, measured position, temperature, input voltage, work load, and communication events.
Stage 5: Apply the representative duty cycle
Repeat the test with the final linkage, payload, acceleration, holding time, and cable arrangement. Record results at the most distant or most heavily loaded actuator.
Compare TTL serial bus with PWM, RS485, and CAN Bus
| Engineering requirement | XQ-BLS325TTL | PWM | RS485/Modbus | CAN Bus |
|---|---|---|---|---|
| Multi-axis node addressing | Suited to addressed servo chains | Usually channel-based | Suited to register-based networks | Suited to distributed CAN networks |
| Shared signal wiring | Daisy-chain candidate | Separate channels often needed | Depends on topology | Depends on CAN topology |
| Position and status feedback | Bidirectional servo telemetry | Depends on controller and servo | Register polling | Message-based feedback |
| Compact robot integration | Useful when nodes and feedback share a bus | Simple for small installations | Useful with industrial controllers | Useful with CAN-capable controllers |
| Main commissioning focus | Node identity, timing, and telemetry | Channel, neutral, and travel | Address, registers, and termination | Node identity and message configuration |
This table is an architecture aid. Confirm the exact protocol and controller interface in the current BLS325TTL documentation before committing to a production design.
Frequently Asked Questions
The main selection case is the combination of the product page’s low-profile chassis reference, 25kg.cm-class output, fast 8.4V response, TTL daisy-chain communication, and actuator-level telemetry for compact multi-axis motion. Confirm the final height from the current drawing because the same page also lists 28.5mm in its specification table.
The product page identifies a TTL daisy-chain topology for multiple synchronized servos. Confirm supported node count, addressing, wiring order, timing, and controller implementation before building the production network.
The product page identifies absolute position, internal temperature, input voltage, and work-load telemetry. Confirm the exact data format, units, update behavior, and invalid-data state in the current documentation.
The product page identifies a 12-bit magnetic encoder for position feedback. Validate the encoder data path, resolution in the final mechanism, calibration process, and behavior under communication interruption.
It can be a better fit when several axes need node identity, shared wiring, coordinated motion, and telemetry. PWM may remain simpler for a single-axis or small conventional RC installation.
That depends on the lever arm, payload, gravity, acceleration, friction, shock, linkage geometry, transmission efficiency, and duty cycle. Calculate the worst-case torque at the selected voltage.
Provide axis count, torque and speed profile, supply voltage, TTL communication requirements, node arrangement, mechanical envelope, payload, duty cycle, controller type, sample quantity, and acceptance criteria.
Final XQ-BLS325TTL selection checklist
Before approving the BLS325TTL for a compact robotic or industrial design, confirm:
- final low-profile envelope and mounting dimensions from the current drawing;
- torque requirement at the actual output lever arm;
- 0.07 sec/60° speed requirement at the validated 8.4V condition;
- TTL controller and protocol compatibility;
- node identities and daisy-chain order;
- command, telemetry, timeout, and recovery behavior;
- position feedback and magnetic encoder requirements;
- voltage at the actuator during simultaneous movement;
- bracket stiffness and external side-load support;
- representative-load and repeated-cycle results;
- service access and actuator replacement procedure.
The XQ-BLS325TTL should be evaluated as a compact networked motion component rather than only as a 25kg.cm servo. Its low-profile chassis reference, 8.4V high-speed operating point, TTL daisy-chain interface, telemetry capability, 12-bit magnetic encoder, brushless motor, stainless-steel gears, CNC-machined aluminum case, and dual ball bearings make it a candidate for compact robotics, RC steering, gimbals, and distributed automation where space and coordinated feedback must be solved together. Confirm the final chassis height from the current mechanical drawing because the product page presents both 27mm and 28.5mm references.