
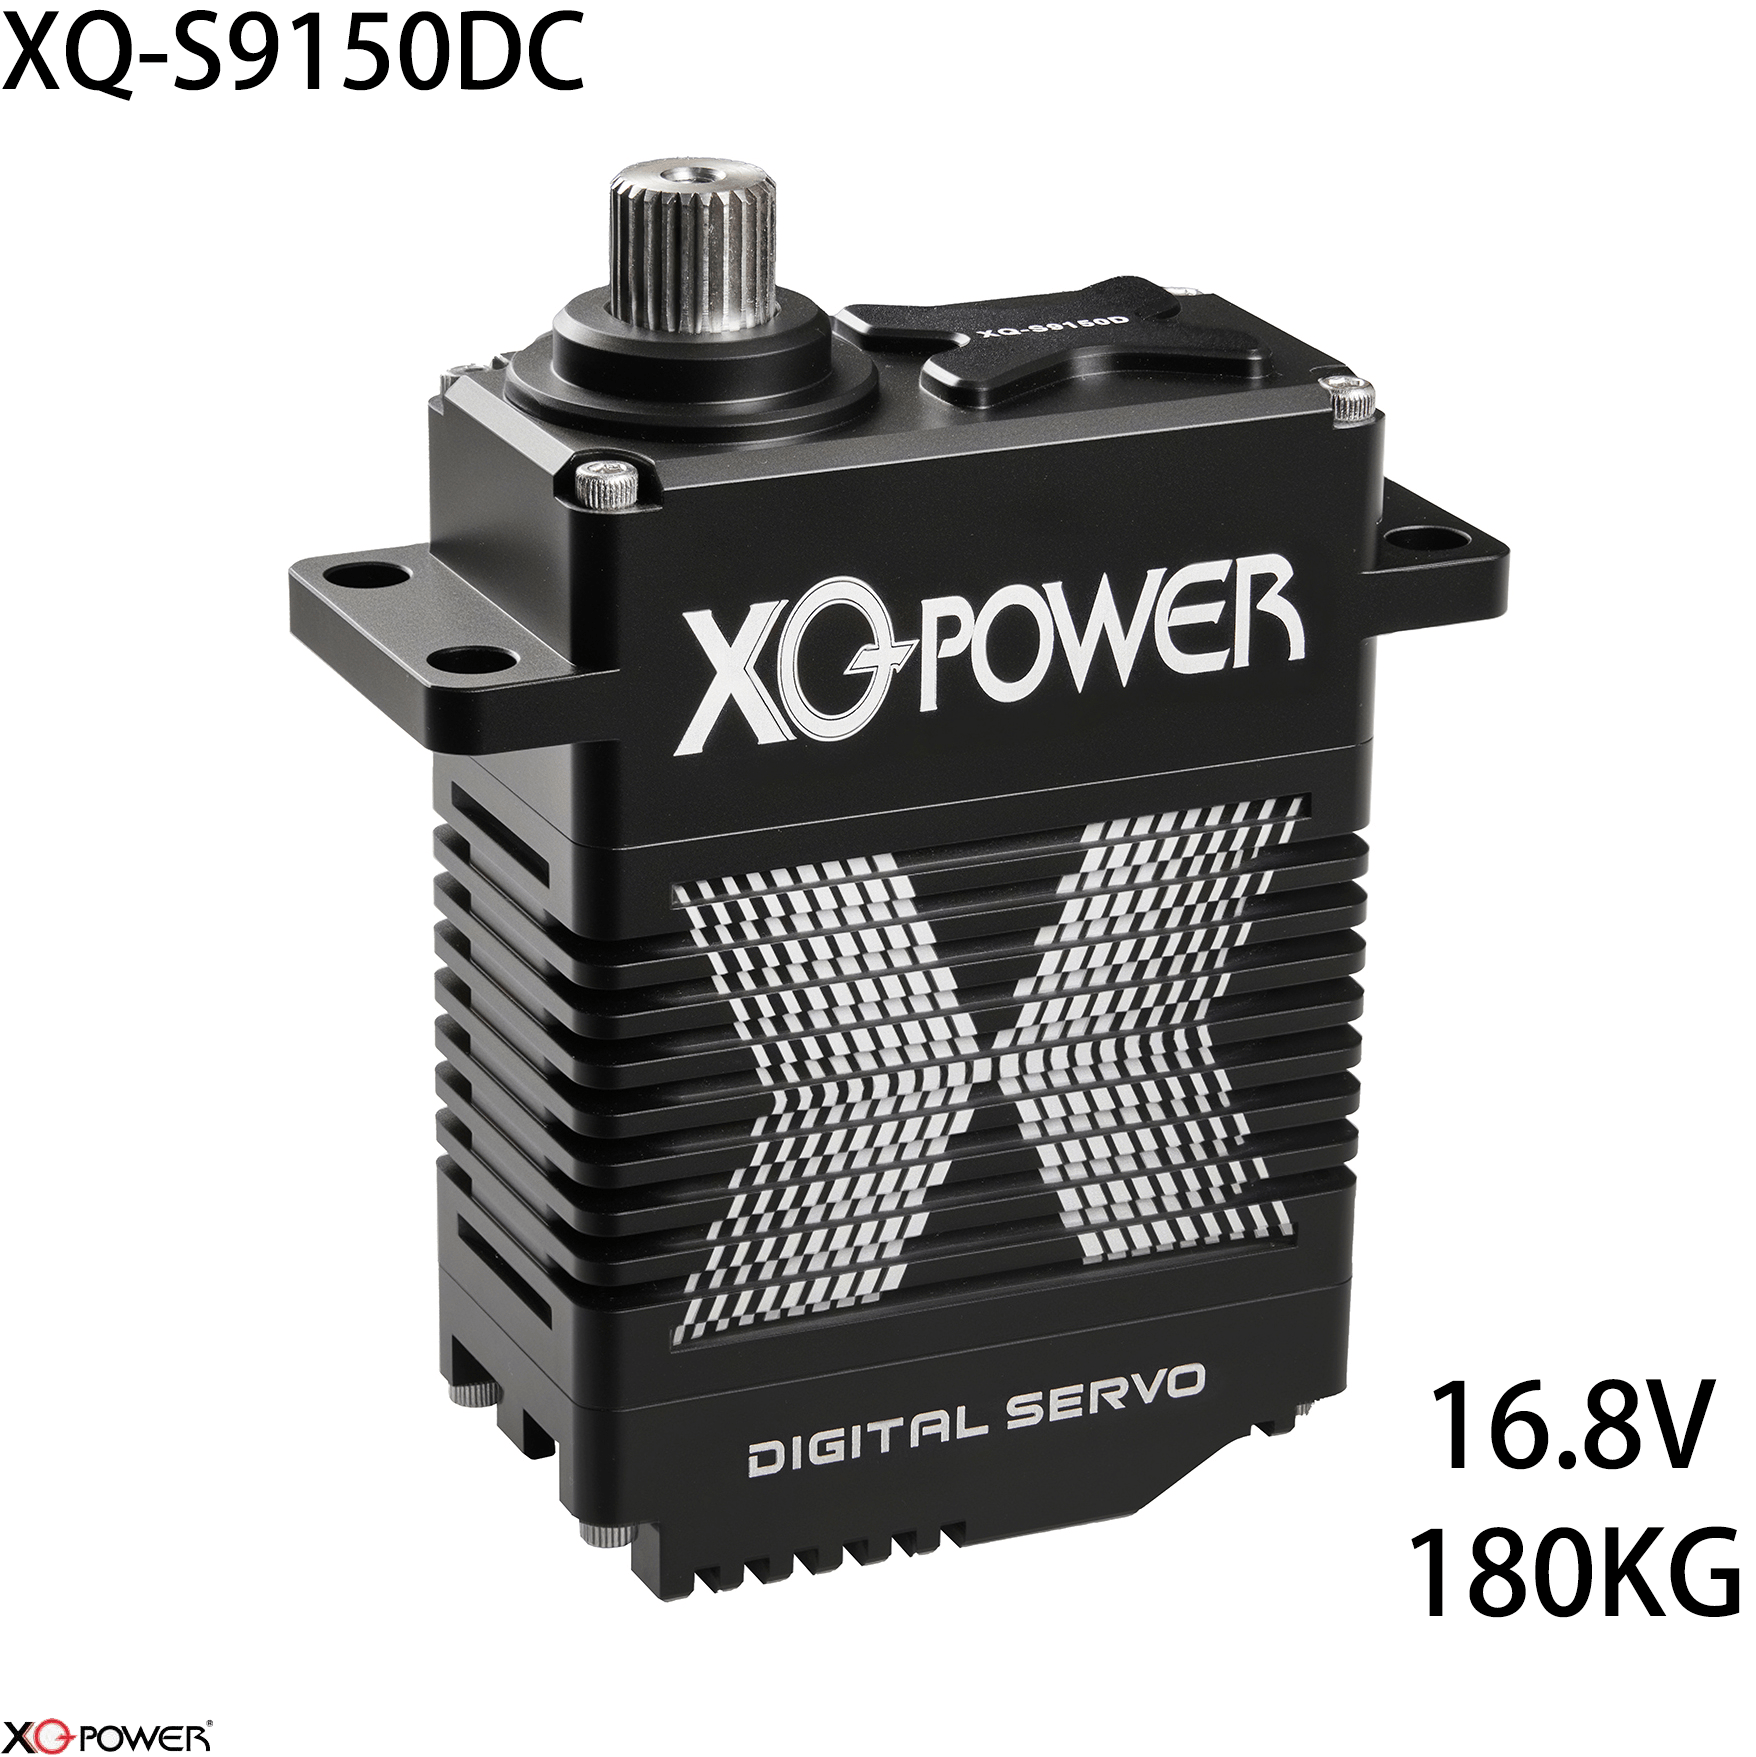
Product Overview
The XQ-S9150DC is a 180kg.cm (2500 oz-in) ultra-high torque brushless actuator engineered for heavy-duty UAVs and robotics. Driven by a brushless BLDC motor through a reinforced toughened steel gear train, it delivers a genuine 180kg.cm stall torque at 16.8V, yet the complete full-CNC 64mm-class unit weighs only 452g — an outstanding torque-to-weight ratio for heavy-lift multirotors, large control surfaces, robotic joints and heavy-duty steering linkages.
What sets the XQ-S9150DC apart is its native CAN Bus interface with UAVCAN support. Rather than a PWM pulse train, every command and telemetry value travels as an addressed CAN frame on a two-wire differential bus. That means CRC-protected, noise-immune digital communication that survives the high-current ESC and motor noise of a large UAV, real-time feedback of position, speed, current and temperature, and multi-actuator daisy-chains on a single bus with individual node IDs — no separate signal harness per actuator.
With a full-CNC aluminium case, reinforced steel gearing and contactless magnetic feedback, the XQ-S9150DC is built for mission-critical operation on heavy-lift UAVs, agricultural drones, industrial robots and automation equipment where a single actuator failure is not an option.
Technical Specifications
| Item | XQ-S9150DC (180kg CAN Bus Industrial Brushless Actuator) |
|---|---|
| Item No. | XQ-S9150DC |
| Size | 64.0 * 32.8 * 76.5 mm |
| Weight | 452 g |
| Gear | Reinforced Toughened Steel |
| Motor | Brushless BLDC |
| Interface | CAN Bus / UAVCAN |
| Voltage | 8.4 – 16.8 V |
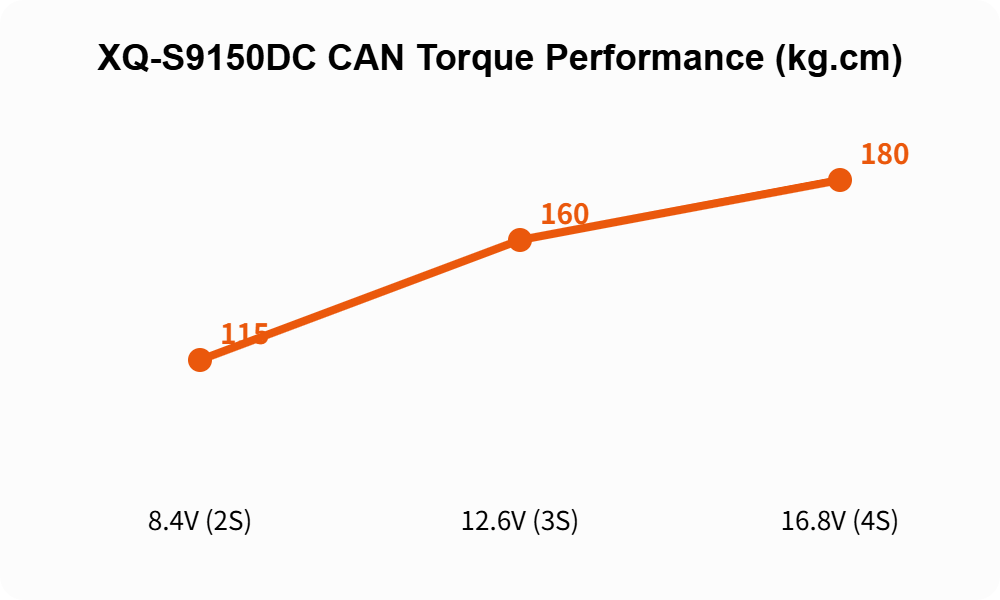
Performance Matrix
| Voltage | Torque (kg.cm) | Torque (oz-in) | Speed (sec/60°) |
|---|---|---|---|
| 8.4 V (2S) | 115 | 1597 | 0.20 |
| 12.6 V (3S) | 160 | 2222 | 0.17 |
| 16.8 V (4S) | 180 | 2500 | 0.14 |
Key Technical Highlights
Optimized for distributed control in large-scale UAVs and industrial robots, ensuring zero-latency motion and robust signal integrity even in high-interference environments.
1. Mission-Critical CAN Bus (UAVCAN) Reliability
On a heavy-lift UAV the actuator harness runs alongside high-current ESC leads, so analogue PWM signals are easily corrupted by induced noise and voltage spikes. The XQ-S9150DC replaces that fragile pulse train with a differential CAN Bus / UAVCAN link: every frame carries a CRC and is acknowledged by the receiver, so a corrupted command is detected and retransmitted instead of being executed as a wrong control-surface deflection. Node addressing lets each actuator on the airframe be identified, health-monitored and updated independently, turning the actuator layer into a self-diagnosing digital subsystem rather than a blind analogue output.
2. UAVCAN Optimization for Flight Controllers
The firmware implements a UAVCAN-compatible node model with standard actuator command and feedback messages, so the actuator integrates cleanly with CAN-capable flight stacks such as PX4 and ArduPilot running on CAN-enabled flight controllers. Position feedback, bus voltage, current draw and internal temperature are published as telemetry, giving the flight controller the data it needs for health monitoring, failsafe logic and post-flight diagnostics. Multiple XQ-S9150DC units can share a single twisted-pair bus with unique node IDs, dramatically simplifying wiring and reducing weight on a large airframe.
3. Unrivaled 180kg.cm Torque & 4S Efficiency
At 16.8V (4S HV) the XQ-S9150DC produces a massive 180kg.cm — roughly 2500 oz-in — of stall torque, while still delivering 115kg.cm at 8.4V and 160kg.cm at 12.6V. That headroom lets it drive large control surfaces, retractable landing gear, cargo release mechanisms, robotic joints and heavy steering linkages directly, without external reduction gearing. The brushless motor maintains high efficiency and low heat build-up even under sustained heavy loads, so the unit stays cool and repeatable through continuous duty cycles.
4. Aerospace-Grade Full-CNC Armor
The 64mm full-CNC aluminium case doubles as a heatsink while shielding the internals from impact and debris. Combined with reinforced toughened steel gearing and contactless magnetic position feedback (no wearing potentiometer tracks), the XQ-S9150DC shrugs off vibration, shock and dust that would destroy a conventional hobby servo, making it suitable for agricultural drones, inspection UAVs and permanently installed outdoor robotics.
Pro Tip: For higher payload requirements, explore our 390kg XQ-S9350DC CAN Bus model.
Frequently Asked Questions
A: Yes. Because the actuator communicates over CAN Bus with UAVCAN-compatible messages, it can be attached to any flight controller that exposes a CAN port and runs PX4 or ArduPilot with the UAVCAN actuator drivers enabled. You simply set a unique node ID for each actuator, wire the units onto the shared CAN twisted pair, and the flight stack can send actuator commands while reading back position, current and temperature telemetry. No PWM signal harness is required.
A: The XQ-S9150DC is designed for the vibration environment of large multirotors and helicopters. Contactless magnetic position feedback replaces the fragile wiper/potentiometer of analogue servos, reinforced toughened steel gearing resists shock loading from rotor-induced oscillation, and the CNC aluminium housing rigidly supports the output shaft to minimise free play. The CAN Bus link itself is differential and CRC-protected, so electrical noise and vibration-induced connector chatter cannot corrupt commands, while internal damped mounting interfaces keep the electronics isolated from airframe resonance.