
Product Overview
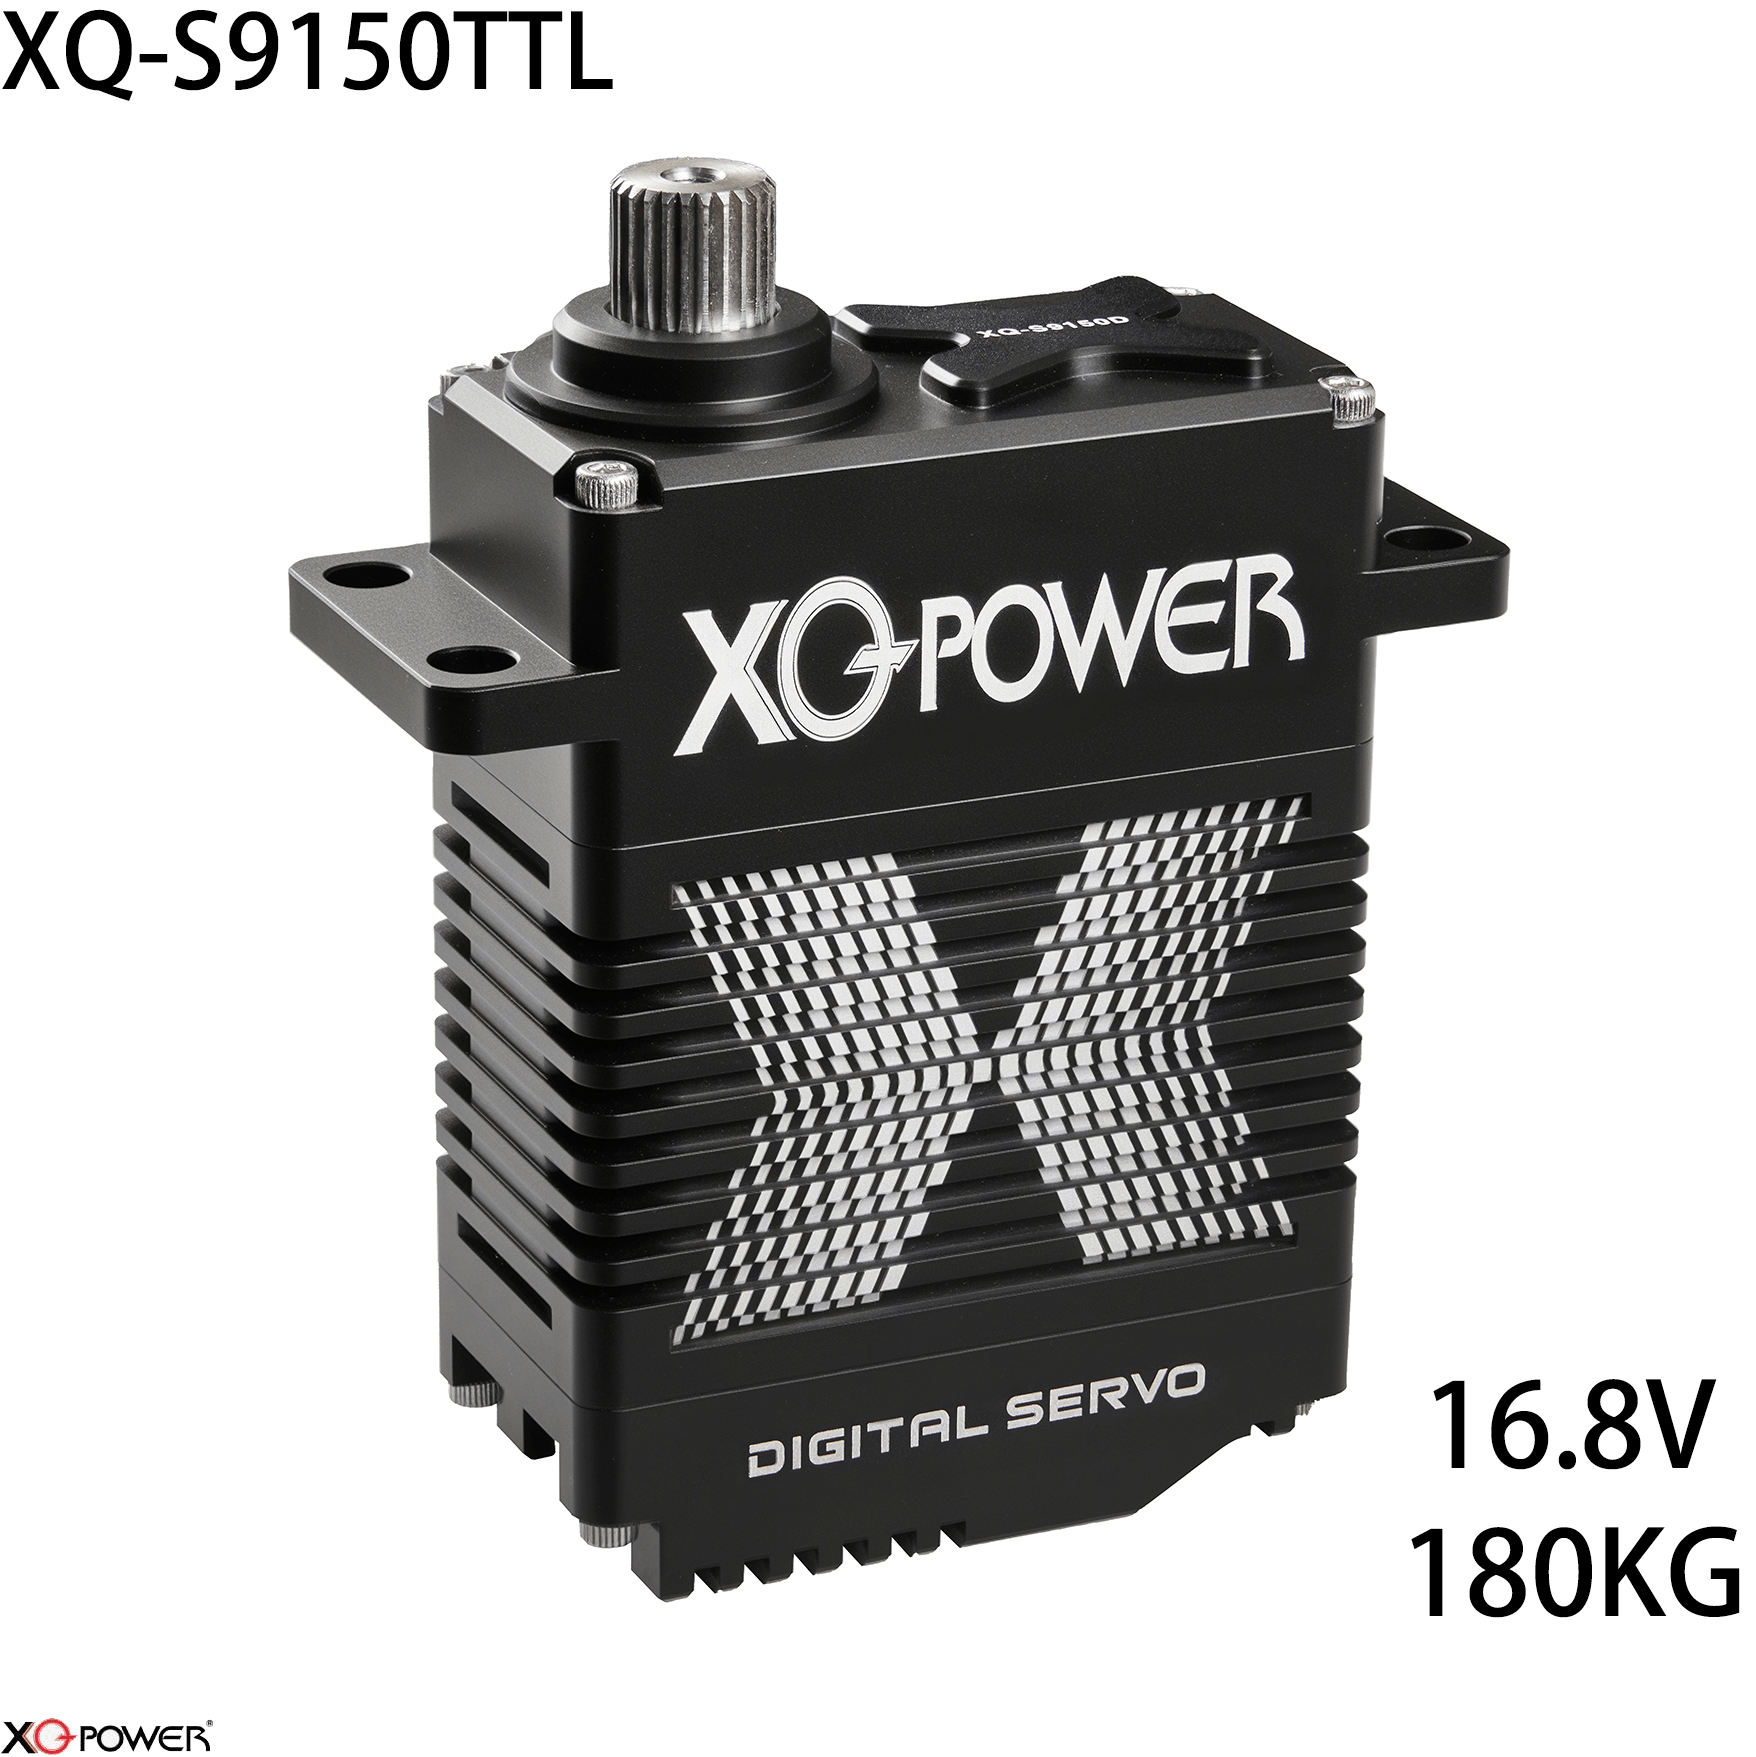
The XQ-S9150TTL is a 180kg.cm ultra-torque smart serial bus brushless actuator engineered for the most demanding heavy-duty robotics applications. A brushless BLDC motor drives a reinforced toughened steel gear train to deliver a genuine 180kg.cm (2500 oz-in) stall torque at 16.8V, while the complete full-CNC unit weighs only 452g — an outstanding torque-to-weight ratio for large robotic joints, heavy gantries and industrial motion axes.
What defines the XQ-S9150TTL is its TTL Serial Bus protocol. Instead of a one-way PWM signal, the actuator communicates over a bidirectional half-duplex TTL bus that allows daisy-chained serial control of dozens of actuators from a single port, plus real-time feedback of position, speed, load and temperature. Each unit carries a unique ID, so commanding a complex multi-axis motion platform is simply a matter of addressing the right ID on the shared bus — dramatically reducing wiring complexity and harness weight.
Built around a 12-bit magnetic encoder, a full-CNC housing and a heavy-duty socket interface, the XQ-S9150TTL is designed for 24/7 deployment on multi-axis robotic arms, humanoid and legged platforms, AGV/AMR steering modules and industrial automation cells where precision, telemetry and durability are mandatory rather than optional.
Technical Specifications
| Item | XQ-S9150TTL (180kg TTL Serial Bus Brushless Actuator) |
|---|---|
| Item No. | XQ-S9150TTL |
| Size | 64.0 * 32.8 * 76.5 mm |
| Weight | 452 g |
| Gear | Reinforced Toughened Steel |
| Motor | Brushless BLDC |
| Interface | TTL Serial Bus |
| Voltage | 8.4 – 16.8 V |
Performance Matrix
| Voltage | Torque (kg.cm) | Torque (oz-in) | Speed (sec/60°) |
|---|---|---|---|
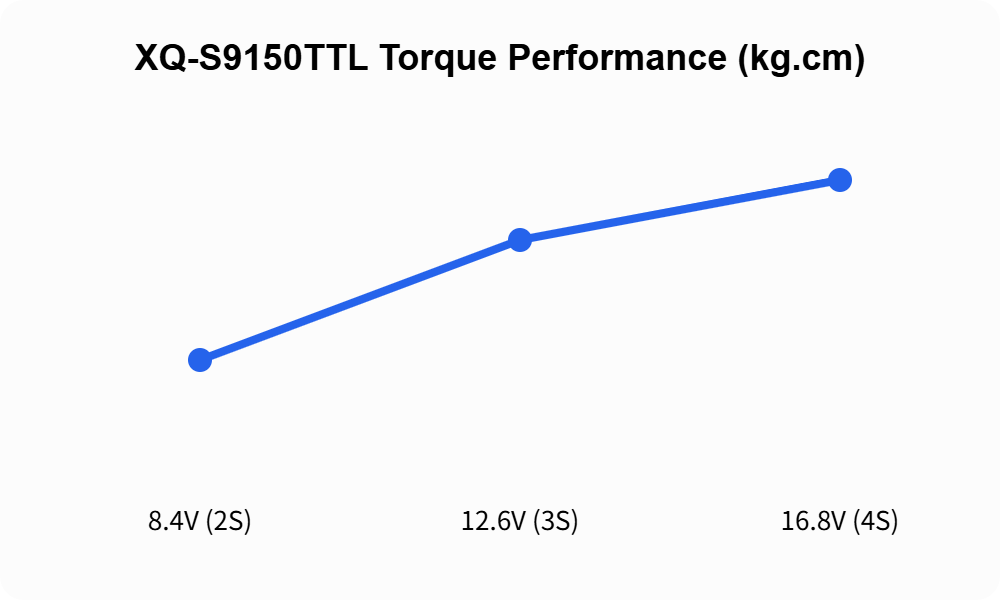
| 8.4 V (2S) | 115 | 1597 | 0.20 |
| 12.6 V (3S) | 160 | 2222 | 0.17 |
| 16.8 V (4S) | 180 | 2500 | 0.14 |
Key Technical Highlights
1. Intelligent Daisy-Chain Control (TTL)
The XQ-S9150TTL speaks a bidirectional TTL Serial Bus protocol. Multiple actuators share a single daisy-chained bus with unique IDs, so a whole multi-axis platform can be wired from one controller port. Real-time bidirectional communication means each actuator can both receive motion commands and report position, speed, load and temperature back to the host — enabling synchronized multi-joint choreography with far less cabling than conventional PWM solutions.
2. Real-Time Telemetry & Closed-Loop Precision
Because the bus is bidirectional, the XQ-S9150TTL streams live telemetry while it moves. A 12-bit (4096-step) magnetic encoder closes the position loop, delivering high-resolution, drift-free feedback with no wearing potentiometer tracks. Controllers can detect stalls, over-temperature and load spikes in real time and react immediately — essential for legged robots, robotic arms and any platform where the machine must know exactly where every joint is.
3. Brushless Endurance & Oversized CNC Armour
A brushless BLDC motor eliminates brush wear and carbon dust entirely, while the oversized full-CNC aluminium case doubles as a heatsink and protects the internal electronics. The result is stable, repeatable accuracy across millions of high-torque cycles and a service life far beyond conventional brushed industrial servos, even in harsh factory or outdoor environments.
4. Heavy-Duty Drivetrain & Socket Interface
The drive train pairs the brushless motor with reinforced toughened steel gears that absorb shock loads and sustain 180kg.cm of stall torque. A professional socket interface keeps power and signal wiring secure and quickly serviceable, so the actuator can be swapped in the field in minutes — ideal for heavy-duty robotic joints, gantries and long-term deployments.
5. Ideal for Space-Constrained High-Torque Joints
Ideal for space-constrained joints requiring massive torque, the S9150TTL combines intelligent serial control with high-precision feedback for professional robotic developers.
Pro Tip: For even heavier loads requiring up to 390kg-cm of torque, consider our flagship XQ-S9350TTL model.
Frequently Asked Questions
Yes. The XQ-S9150TTL uses a TTL Serial Bus, so multiple actuators — including compatible serial bus servos — can be chained on a single bus and addressed individually by their unique IDs. All units share one communication port on the host controller, which slashes wiring complexity and harness weight while still allowing per-actuator commands and per-actuator feedback.
A 12-bit magnetic encoder provides 4096 counts of resolution per revolution, so the actuator resolves position far more finely than a conventional analogue feedback pot. Because it is contactless it never wears out or drifts, giving long-term, repeatable accuracy and enabling precise closed-loop control of position, speed and torque — crucial for multi-axis arms and legged platforms where small joint errors compound quickly.