
1. Introduction: Why 1000kg Torque Is a System Result
Reaching 1000kg servo torque output is not about increasing motor size.
It is the result of a full actuator system design.
Modern robotics requires compact actuators with extremely high output force.
This makes torque density and mechanical efficiency more important than raw motor power.
2. 1000kg servo torque High-Efficiency Motor Foundation
Every servo actuator starts with a compact high-performance motor.
Key design elements include:
- High magnetic flux density rotor
- High copper fill stator winding
- Efficient current handling design
- Stable thermal structure for continuous load
This stage provides the initial torque source before mechanical amplification.
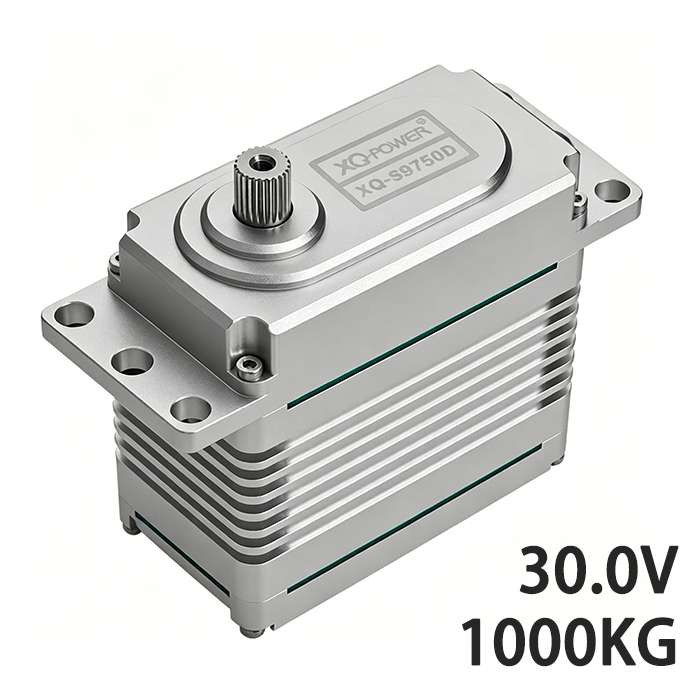
3. 1000kg servo torque Multi-Stage Gear Amplification System
The most critical factor in achieving high output is the gearbox.
A multi-stage planetary gear system increases output torque through mechanical reduction.
Key features:
- High-strength metal gear train
- Optimized gear ratio design
- Low backlash structure for precision control
- High mechanical efficiency under load
At this stage, torque is significantly amplified through mechanical transmission.
4. Structural Load-Bearing Design
High torque output must be supported by a rigid structure.
Without structural strength, torque cannot be safely delivered.
Key engineering elements:
- Reinforced aluminum alloy housing
- High-load output shaft design
- Optimized bearing support system
- Anti-deformation mechanical layout
This ensures stable operation under extreme load conditions.
5. Closed-Loop Magnetic Encoder Control
Precision is essential when dealing with high force output.
A magnetic encoder enables real-time feedback of position and movement.
This allows:
- Accurate angle control
- Stable torque output under load changes
- Reduced mechanical overshoot
- Smooth low-speed operation
Closed-loop control ensures the actuator uses its full mechanical capability safely and efficiently.
6. Thermal Management for Continuous Operation
Peak torque is not the challenge.
Sustained torque is.
Heat is the main limiting factor in high-load systems.
To solve this, the actuator uses:
- Aluminum housing for heat conduction
- Optimized internal thermal path
- Efficient heat dissipation structure
This ensures stable performance under long-term load.
7. System Integration Philosophy
High performance cannot come from a single component.
A complete actuator integrates:
- Motor
- Gear system
- Encoder feedback
- Control electronics
- Mechanical housing
Only when all systems are matched can extreme output levels be achieved.
This system-level design approach is what enables consistent high-force performance in robotics applications.
8. Application Scenarios
This type of actuator is widely used in:
- Humanoid robot joints
- Heavy-duty robotic arms
- Industrial automation systems
- UAV and gimbal systems
9. Learn More About Our Engineering
You can explore more about our design philosophy in:
Solutions
Powering Innovation
Contact XQ-power’s product specialist to recommend suitable motor or servo for your product.