
A client recently asked me: “My motor is rated for 1000kg. Can I hold that load indefinitely?” This question leads us directly to stall torque.
Simply put, this metric represents the maximum torque produced when the shaft stops rotating. In heavy-duty robotics, this happens often. Think of a robotic gripper holding a heavy object in a fixed position.
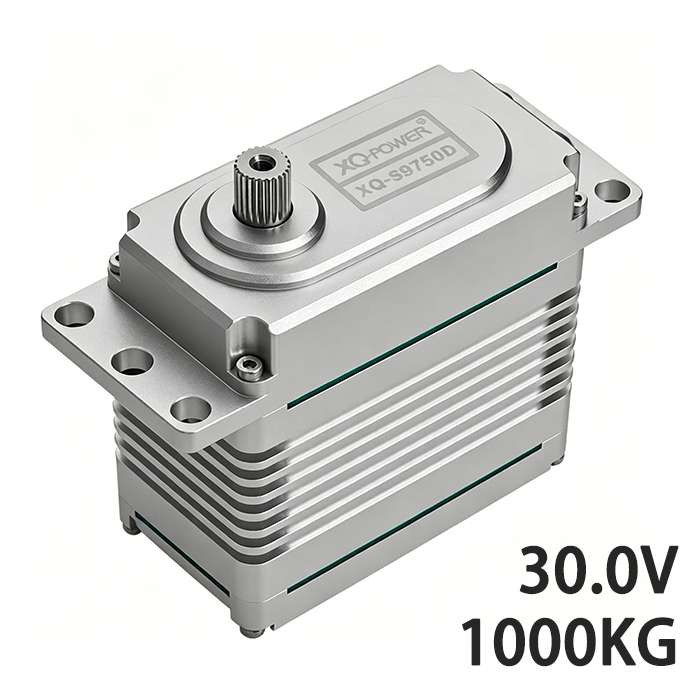
Here is the catch. At stall torque, the motor consumes maximum current. There is no back-EMF to counteract the power. Essentially, the motor becomes a heater. Most standard servos will smoke if you hold them at this state for more than a few seconds.
Designing a system for massive loads? Don’t just look at the stall torque number. Look for high thermal thresholds or built-in current limiting. At XQ-Power, we design our series to handle these “holding” states safely. However, we always suggest using mechanical brakes for long static holds. It is simply safer engineering.