
Product Overview
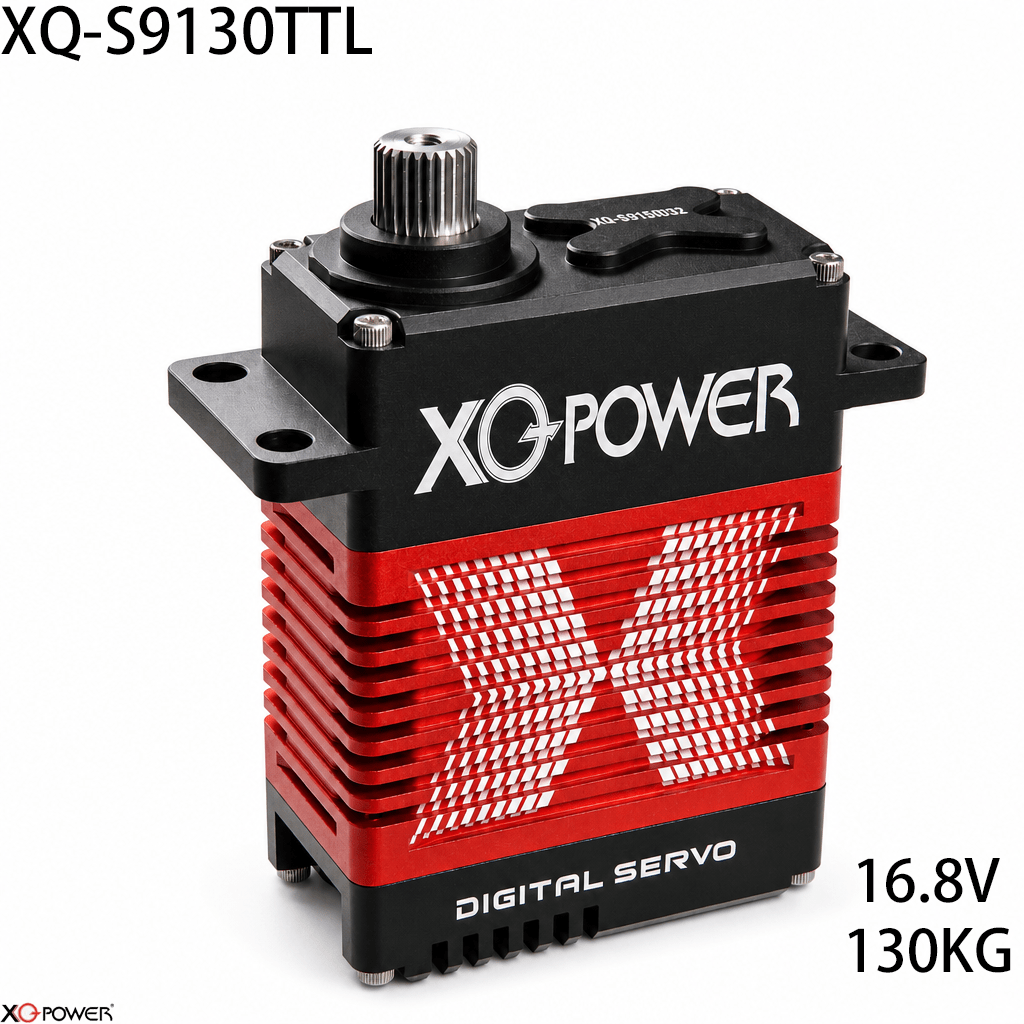
The XQ-S9130TTL is a heavyweight smart serial-bus actuator built for heavy-duty robotics, large robotic joints and industrial motion systems. Combining a high-efficiency brushless motor with a toughened steel gear train, it delivers a massive 130kg.cm stall torque at 16.8V (4S) HV input — enough to move payloads that conventional servos cannot. Its native 16.8V efficiency means less current sag, lower heat build-up and more usable power per amp, so heavy-duty robots, giant-scale gimbals, pan-tilt heads and rugged field equipment can run harder and longer on the same battery. The TTL serial bus interface adds closed-loop intelligence: position, speed, load and temperature telemetry are readable in real time, making the XQ-S9130TTL a true smart actuator rather than a simple motor.
Technical Specifications
| Item | XQ-S9130TTL (Smart Serial Bus Brushless Actuator) |
|---|---|
| Item No. | XQ-S9130TTL |
| Size | 64.0 * 33.0 * 76.0 mm |
| Weight | 411 g (14.5 oz) |
| Gear | Toughened Steel |
| Motor | Brushless |
| Interface | TTL Serial Bus (half-duplex, daisy-chain capable) |
| Voltage | 8.4 – 16.8 V (2S – 4S HV) |
| Sensor | 12-bit Magnetic Encoder (4096 steps) |
Performance Matrix
| Voltage | Speed (sec/60°) | Stall Torque (kg.cm) |
|---|---|---|
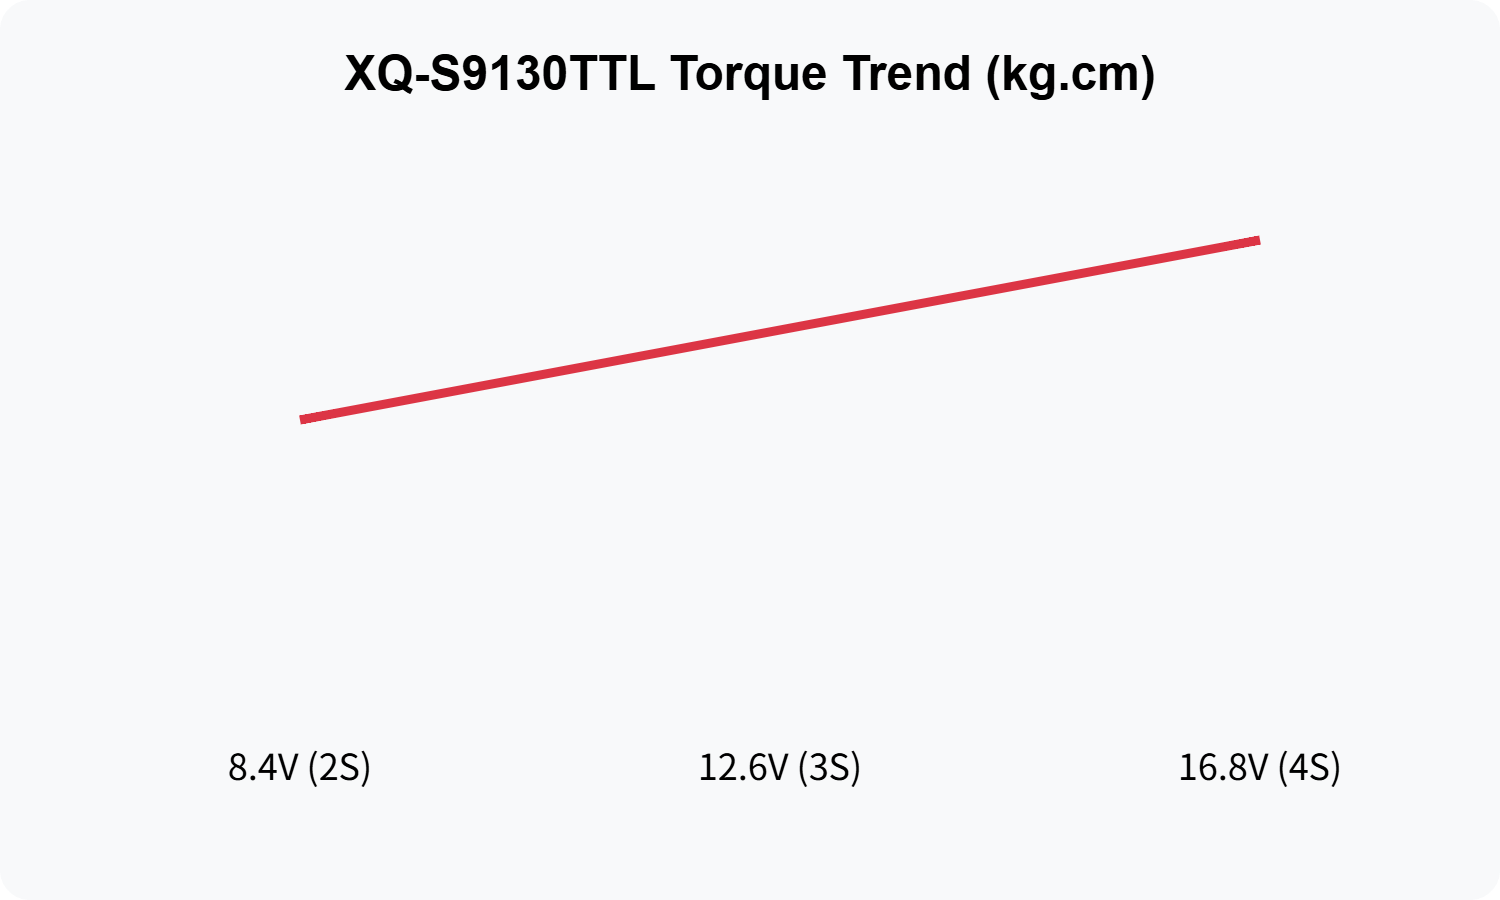
| 8.4 V (2S) | 0.28 | 100 |
| 12.6 V (3S) | 0.17 | 115 |
| 16.8 V (4S) | 0.14 | 130 |
Key Technical Highlights
1. Intelligent Daisy-Chain Control (TTL)
A single half-duplex TTL serial bus lets you connect multiple XQ-S9130TTL actuators in one daisy chain, each addressed by its own unique ID. That means far fewer wires, faster installation and dramatically simpler cable routing on multi-axis robotic arms, walking platforms and animatronic rigs — one controller port can command an entire axis group while every unit reports back on the same line.
2. Real-Time Telemetry & Closed-Loop Precision
The 12-bit magnetic encoder gives 4096-step resolution and constant feedback of position, speed, load and temperature. Because control is closed-loop, the actuator continuously corrects itself against gravity and external loads, holding commanded angles with almost no drift, resisting back-driving, and flagging overload or over-temperature conditions before they become failures.
3. Brushless Endurance & Oversized CNC Armour
A brushless motor removes brushes and commutator wear entirely, so the XQ-S9130TTL runs cooler, more efficiently and for millions of cycles without maintenance. The oversized CNC-machined aluminium case adds structural rigidity and doubles as a heatsink, while the toughened steel gear train and stainless shafts handle repeated 130kg.cm loads with minimal backlash.
4. Field-Serviceable Socket Interface
The replaceable socket-style wiring interface means damaged leads can be swapped in the field instead of scrapping the whole unit, cutting downtime and total cost of ownership.
Specifying the XQ-S9130TTL on a Multi-Axis Bus
The XQ-S9130TTL is normally picked for its bus first and its torque second. Every actuator on the shared half-duplex TTL line carries a unique ID, so a single controller port can command an axis group while position, speed, load and temperature report back over the same cable — attractive on multi-axis robotic arms, walking platforms and animatronic rigs where cable count drives cost. Output steps with the pack: 130kg.cm and 0.14 sec/60° at 16.8V (4S), 115kg.cm at 12.6V (3S), 100kg.cm at 8.4V (2S). For angle holding under gravity and external load, the 12-bit magnetic encoder (4096 steps) supplies closed-loop feedback, and the 64.0*33.0*76.0mm / 411g (14.5oz) all-metal body with toughened steel gearing fits large robotic joints, giant-scale gimbals, pan-tilt heads and rugged field equipment. Where a conventional PWM interface is wanted instead, the 130kg class also includes the XQ-S9130D brushless servo.
Frequently Asked Questions
Because the TTL serial bus is a shared half-duplex line, each actuator on the chain is assigned a unique ID before installation and every command packet carries that ID. Practical chain length depends on your controller’s bus current capability and total cable run; keeping the daisy chain to roughly 10-15 high-torque units per port, using a well-regulated 16.8V supply and adequate bus power injection along the chain, gives the most reliable performance in heavy-duty multi-axis builds.
A 12-bit magnetic encoder provides 4096 steps of absolute position feedback and, unlike a potentiometer, has no physical wiper to wear out, no dead band at the ends of travel and no sensitivity to dust, moisture or vibration. That translates into smoother low-speed motion, far more precise angle holding under load, full 360°-class position awareness, and real-time telemetry of load and temperature — all of which are essential for closed-loop robotic joints that must repeat the same move thousands of times without drifting.
Take Action
Ready to deploy the absolute pinnacle of torque and precision? The XQ-S8060D provides the ultimate heavy-duty motion solution for professional robotic and industrial projects.